01
Multisensor perception
Combines complementary sensing modalities to improve situational awareness across varied conditions.
MANAR is a search-and-rescue drone project built around multisensor perception, deterministic flight control, and human review for consequential actions.
Project approach
Combines complementary sensing modalities to improve situational awareness across varied conditions.
Automates repeatable search tasks while keeping important operational decisions under human oversight.
Calm, technically credible, civilian system design focused on search, verification, and guidance.
Hardware Architecture
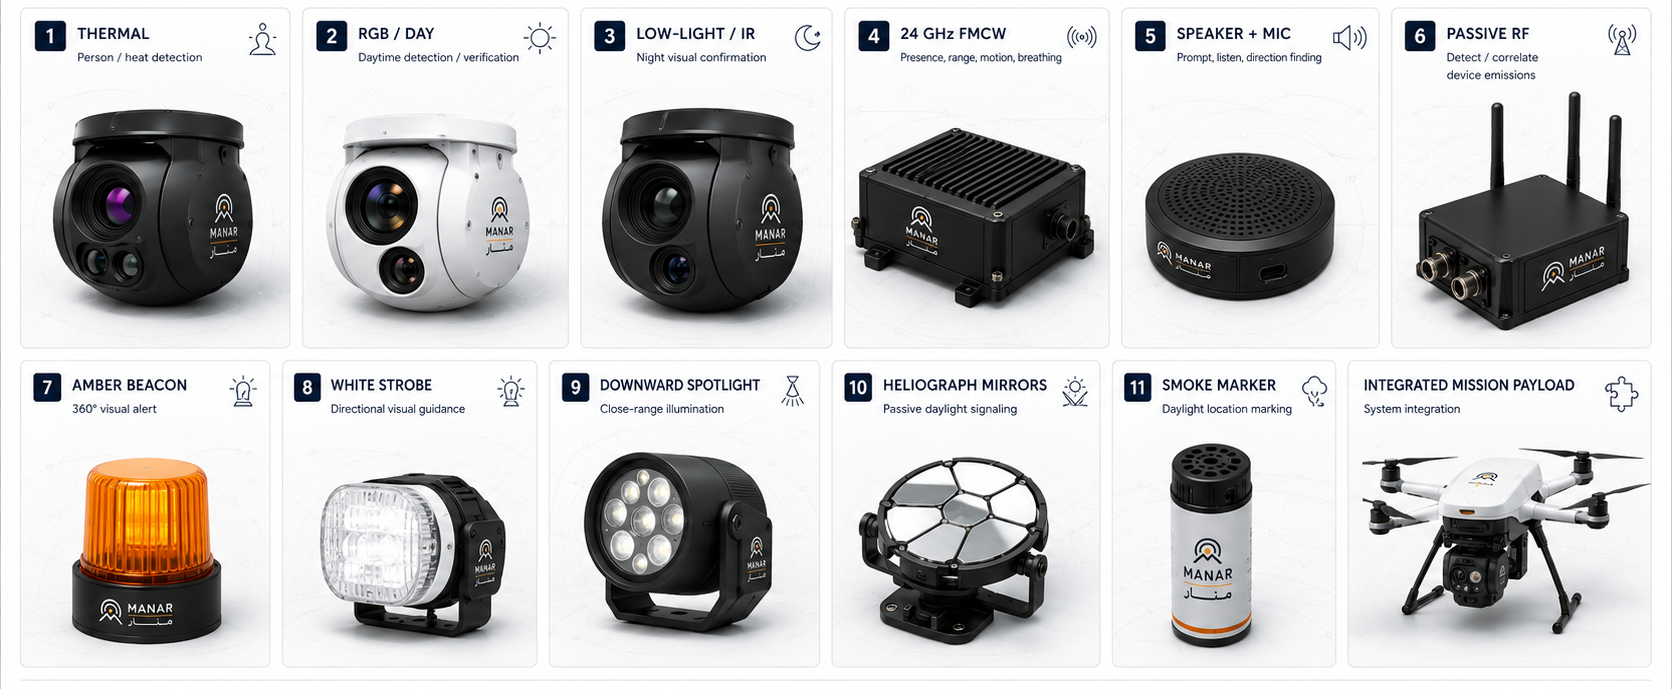
| Component | Primary role |
|---|---|
| Thermal | Person/heat detection |
| RGB/day | Daytime detection/verification |
| Low-light/IR | Night visual confirmation |
| 24 GHz FMCW | Presence, range, motion, breathing |
| Speaker + mic | Prompt, listen, direction finding |
| Passive RF | Detect/correlate device emissions |
| Amber beacon | 360° visual alert |
| White strobe | Directional visual guidance |
| Downward spotlight | Close-range illumination |
| Heliograph mirrors | Passive daylight signaling |
| Smoke marker | Location/wind marking |
| Milestone | Status |
|---|---|
| Initial Ideation | Completed ✓ |
| GitHub Repository creation | Completed ✓ |
| Initial Branding | Completed ✓ |
| Project scope hardening | Completed ✓ |
| Project limitations and constraints | Completed ✓ |
| Basic web dashboard — v1.0 | Completed ✓ |
| Landing Page | Completed ✓ |
| To be determined... | Planned ⋯ |
| To be determined... | Planned ⋯ |
| LaTeX Report, Presentation and Full documentation | Planned ⋯ |
| Final Publishing & LinkedIn Post | Planned ⋯ |
| Repository Maintenance | Planned ⋯ |
Project repository
See the current project overview, milestones, and public portfolio materials.